#include <LiftingColumn_controller.h>
Inheritance diagram for ControlAPI::LiftingColumnCommandMovementPackage:
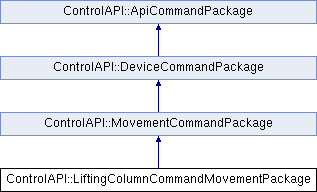
Public Member Functions | |
| virtual void | cloneFrom (DeviceCommandPackage *other) override |
| clone from another device package - should be implemented for custom types. More... | |
 Public Member Functions inherited from ControlAPI::MovementCommandPackage | |
| virtual std::shared_ptr< DeviceCommandPackage > | createSharedPtr () override |
| virtual std::string | className () override |
| Public Member Functions inherited from ControlAPI::DeviceCommandPackage | |
| virtual DeviceCommandPackage * | prepareUpdatePackage () |
| Creates/Returns the DeviceCommandPackage to be used for updates to a running command. Update package will be a shallow copy of this package. It is expected that markUpdatePackageReady() be called after update package is altered. More... | |
| void | markUpdatePackageReady () |
| signal the update package is ready to be used in running commands. prepareUpdatePackage() should be called first. | |
Public Attributes | |
| bool | expectStall = false |
| stall expected flag - set to true if expecting a stall. (useful to home against mechanical limit) More... | |
| Public Attributes inherited from ControlAPI::MovementCommandPackage | |
| float | disp_target = 0.0f |
| Position Target ex: (Millimeters) | |
| float | vel_target = 0.0f |
| Vel Target ex: (Millimeters/S) | |
| float | acc_target = 0.0f |
| Acc Target ex: (Millimeters/S^2) | |
| bool | disp_absolute = true |
| whether position should be global to device or relative to starting position when command starts. | |
| bool | trackDisp = true |
| Enable Track Displacement Target. | |
| bool | trackVel = true |
| Track Velocity Target (if vel_target is non-zero) | |
| bool | trackAcc = true |
| Track Acceleration Target (if acc_target is non-zero) | |
| Units | units |
| units | |
| Public Attributes inherited from ControlAPI::DeviceCommandPackage | |
| bool | continuous = false |
| set to true if command is a continous (async/time consuming) command or if it is desired that the command run indefinitely. (tracking command etc) set to false if the command should terminate once a target is reached. | |
| Public Attributes inherited from ControlAPI::ApiCommandPackage | |
| std::string | alias |
| user definable unique alias for this command package | |
Additional Inherited Members | |
| Public Types inherited from ControlAPI::MovementCommandPackage | |
| enum | Units { Units_Millimeters, Units_Degrees } |
| Static Public Member Functions inherited from ControlAPI::MovementCommandPackage | |
| static std::string | staticClassName () |
| Static Public Member Functions inherited from ControlAPI::DeviceCommandPackage | |
| static std::string | staticClassName () |
| Static Public Member Functions inherited from ControlAPI::ApiCommandPackage | |
| static std::string | staticClassName () |
Detailed Description
Movement command for roboclaw.
Member Function Documentation
◆ cloneFrom()
| overridevirtual |
clone from another device package - should be implemented for custom types.
- Parameters
-
other
Reimplemented from ControlAPI::MovementCommandPackage.
Member Data Documentation
◆ expectStall
| bool ControlAPI::LiftingColumnCommandMovementPackage::expectStall = false |
stall expected flag - set to true if expecting a stall. (useful to home against mechanical limit)
The documentation for this class was generated from the following file:
- LiftingColumn_controller/LiftingColumn_controller.h