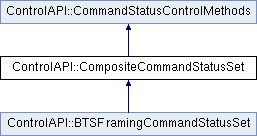
base class for giving access to composite command status sets. and functions to manage groups of commands etc. More...
#include <Composite_Control.h>
Public Member Functions | |
| virtual bool | runFull () override |
| initializes, and runs the command until it stops (blocking) More... | |
| virtual bool | runASync () override |
| initialize and start the command async. More... | |
| virtual bool | initialize () override |
| Start the command by internally initializing the thread, binding to the device, and ensuring it is ready to be updated. More... | |
| virtual bool | updateoverride (bool stepped=false) |
| virtual bool | waitUpdateReady () override |
| Wait until command is ready to begin a update step More... | |
| virtual bool | waitUpdateReadyOrFinished () override |
| Wait until command is ready to begin an update step or it is finished. More... | |
| virtual void | waitFinished () override |
| Wait for the command to finish. More... | |
| virtual void | stop () override |
| End the command (cancel) | |
| virtual bool | isBusy () const override |
| returns true if the command is currently running | |
| virtual bool | isFinished () const override |
| returns true if the command has finished. (normally finished or cancelled). | |
| virtual bool | isCancelled () const override |
| returns true if the command was cancelled. | |
 Public Member Functions inherited from ControlAPI::CommandStatusControlMethods | |
| virtual std::string | className () |
| virtual bool | update (bool stepped=false)=0 |
| update the command by allowing it to begin. if stepped = true, will begin to perform 1 update. if stepped = false, will update until finished. More... | |
| virtual bool | isUpdateStepReady () const =0 |
| virtual bool | isSuccessful () const =0 |
Additional Inherited Members | |
| Static Public Member Functions inherited from ControlAPI::CommandStatusControlMethods | |
| static std::string | staticClassName () |
Detailed Description
base class for giving access to composite command status sets. and functions to manage groups of commands etc.
Member Function Documentation
◆ initialize()
| inlineoverridevirtual |
Start the command by internally initializing the thread, binding to the device, and ensuring it is ready to be updated.
- Returns
Implements ControlAPI::CommandStatusControlMethods.
◆ runASync()
| inlineoverridevirtual |
◆ runFull()
| inlineoverridevirtual |
initializes, and runs the command until it stops (blocking)
- Returns
Implements ControlAPI::CommandStatusControlMethods.
◆ waitFinished()
| inlineoverridevirtual |
Wait for the command to finish.
Implements ControlAPI::CommandStatusControlMethods.
◆ waitUpdateReady()
| inlineoverridevirtual |
Wait until command is ready to begin a update step
- Returns
Implements ControlAPI::CommandStatusControlMethods.
◆ waitUpdateReadyOrFinished()
| inlineoverridevirtual |
Wait until command is ready to begin an update step or it is finished.
- Returns
Implements ControlAPI::CommandStatusControlMethods.
The documentation for this class was generated from the following file:
- Composite_Control/Composite_Control.h