Primary class for managing upper-level control over a multi-axis system with different devices. Supports addition of Devices, Controllers, and Control/Commands. More...
#include <HC_API.h>
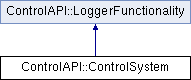
Inheritance diagram for ControlAPI::ControlSystem:
Public Member Functions | |
| virtual std::string | className () override |
| ControlSystem (ControlSystem &system) | |
| void | addDeviceController (DeviceController *controller) |
| Add a device controller to the control system. | |
| virtual void | initializeDevices () |
| initFriendlyNameBuffer (start initial communication and do checks) on all added controllers/devices | |
| virtual void | initializeController (DeviceController *controller) |
| initFriendlyNameBuffer an added device controller. | |
| virtual void | unInitialize () |
| De initialize the control system. disconnecting all controllers and devices. user created controllers and devices should remain allocated while this function is called - then can be freed/released afterwards. More... | |
| void | muteConsole () |
| Mute info messages on console. | |
| void | unMuteConsole () |
| UnMute info message on console. | |
| CommandStatus * | delay (std::string deviceAlias, float time_s) |
| Add a time delay command to a device. | |
| CommandStatus * | delay (DeviceInfo *devInfo, float time_s) |
| Add a time delay command to a device. | |
| CommandStatus * | addDeviceCommand (DeviceInfo *device, DeviceCommandPackage *package) |
| Add a command to a device. | |
| CommandStatus * | addDeviceCommandAlias (std::string deviceAlias, DeviceCommandPackage *package) |
| Add a command to a device using device alias string. | |
| CommandStatus * | addDeviceCommandDevId (int deviceId, DeviceCommandPackage *package) |
| Add a command to a device using device id. | |
| DeviceInfo * | getDeviceFromAlias (std::string deviceAlias) |
| Get a device from its alias string. | |
| DeviceController * | getControllerFromAlias (std::string controllerAlias) |
| Get a controller from its alias string. | |
| void | runFullCommandListSeq (std::vector< CommandStatus * > commandList) |
| Run Commands in order, one after another, fully More... | |
| void | runFullCommandListParallel (std::vector< CommandStatus * > commandList) |
| Run Commands in parallel More... | |
| void | runASyncCommandList (std::vector< CommandStatus * > commandList) |
| Start the list of commands running async, returns immediately. More... | |
| void | waitFinishedCommandList (std::vector< CommandStatus * > commandList) |
| Wait for the list of commands to complete More... | |
| void | setCommandCallback (std::shared_ptr< CommandCallbacks > callbackObj) |
| Attach a CommandCallbacks object to the ControlSystem. | |
 Public Member Functions inherited from ControlAPI::LoggerFunctionality | |
| std::shared_ptr< spdlog::logger > | getLogger () |
| std::string | loggerName () |
Static Public Member Functions | |
| static std::string | staticClassName () |
| Static Public Member Functions inherited from ControlAPI::LoggerFunctionality | |
| static std::string | staticClassName () |
Additional Inherited Members | |
| Protected Attributes inherited from ControlAPI::LoggerFunctionality | |
| std::shared_ptr< spdlog::logger > | logger |
| ControlSystem * | controlSystem = nullptr |
Detailed Description
Primary class for managing upper-level control over a multi-axis system with different devices. Supports addition of Devices, Controllers, and Control/Commands.
Member Function Documentation
◆ runASyncCommandList()
| void ControlAPI::ControlSystem::runASyncCommandList | ( | std::vector< CommandStatus * > | commandList | ) |
Start the list of commands running async, returns immediately.
- Parameters
-
commandList
◆ runFullCommandListParallel()
| void ControlAPI::ControlSystem::runFullCommandListParallel | ( | std::vector< CommandStatus * > | commandList | ) |
Run Commands in parallel
- Parameters
-
commandList
◆ runFullCommandListSeq()
| void ControlAPI::ControlSystem::runFullCommandListSeq | ( | std::vector< CommandStatus * > | commandList | ) |
Run Commands in order, one after another, fully
- Parameters
-
commandList
◆ unInitialize()
| virtual |
De initialize the control system. disconnecting all controllers and devices. user created controllers and devices should remain allocated while this function is called - then can be freed/released afterwards.
◆ waitFinishedCommandList()
| void ControlAPI::ControlSystem::waitFinishedCommandList | ( | std::vector< CommandStatus * > | commandList | ) |
Wait for the list of commands to complete
- Parameters
-
commandList
The documentation for this class was generated from the following file: