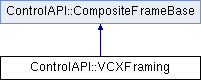
DEPRECIATED. VCX Framing class, contains methods for control of VCX frames. all dimension Units are in millimeters More...
#include <Composite_Control_VCX.h>
Public Member Functions | |
| void | initialize (ControlSystem *system) |
| void | mountBase_GoTo_Home () |
| void | mountBase_Go_MechanicalOriginFrame (const Vector3D &mechSpace, float omega) |
| void | mountBase_Go_ChartCenterFrame (const Vector3D &chartSpace, float omega) |
| void | mountBase_Go_HomeFrame (const Vector3D &displacement, float omega) |
| Vector3D | chartCenterFrame_To_MechanicalOriginFrame (Vector3D chartCenterSpace) |
| transform vector in the chartcenter frame to the mechanical origin frame. More... | |
| Vector3D | targetMountHomeFrame_To_MechanicaOriginFrame (Vector3D homeSpace) |
| transform vector in the home frame to the mechanicalorigin frame. (offset) More... | |
| Vector3D | mechanicalOriginFrame_To_HomeFrame (Vector3D mechanicalSpace) |
| transform vector in the mechanicalorigin frame to the home frame. More... | |
| Vector3D | mountBaseFrame_To_MechanicalOriginFrame (Vector3D mountbaseSpace) |
| transform vector in mountbase space to mechanical origin frame space. More... | |
Public Attributes | |
| Vector3D | chartCenter__MechanicalOriginFrame = {0, 1157.1, 491} |
| chart center position Relative to mechanical base point. "Vector B" Units: millimeters More... | |
| Vector3D | home__MechanicalOriginFrame = {0, 904.8, 1978 } |
| Home position of table relative to mechanical base point. "Vector A" Units: millimeters More... | |
| Vector3D | camera_MountBaseFrame = {0, 24.1, -152.4} |
| Camera position relative to the MountBaseFrame. More... | |
| Vector3D | mountBase_MechanicalOriginFrame |
| current target mount position in the mechanical origin frame. | |
| float | mountBase_Omega_MechanicalOriginFrame |
| current rotation of MountBase in the mechanicalOrigin frame. | |
| Vector3D | camera_MechanicalOriginFrame |
| Current Camera position in mechanicalorigin Frame. More... | |
| Vector3D | camera_ChartCenterFrame |
| Current Camera Position in ChartCenter Frame. More... | |
| std::string | zaberPort |
| Serial Port for zaber (ex "COM4") More... | |
| std::string | liftingColumnPort |
| Serial Port for Lifting Column. (ex "COM5") More... | |
 Public Attributes inherited from ControlAPI::CompositeFrameBase | |
| ControlSystem * | system = nullptr |
Additional Inherited Members | |
| Protected Attributes inherited from ControlAPI::CompositeFrameBase | |
| std::shared_ptr< CompositeFrameBaseInternals > | internals |
Detailed Description
DEPRECIATED. VCX Framing class, contains methods for control of VCX frames. all dimension Units are in millimeters
Member Function Documentation
◆ chartCenterFrame_To_MechanicalOriginFrame()
transform vector in the chartcenter frame to the mechanical origin frame.
- Parameters
-
chartCenterSpace
- Returns
◆ mechanicalOriginFrame_To_HomeFrame()
transform vector in the mechanicalorigin frame to the home frame.
- Parameters
-
mechanicalSpace
- Returns
◆ mountBaseFrame_To_MechanicalOriginFrame()
transform vector in mountbase space to mechanical origin frame space.
- Parameters
-
mountbaseSpace
- Returns
◆ targetMountHomeFrame_To_MechanicaOriginFrame()
transform vector in the home frame to the mechanicalorigin frame. (offset)
- Parameters
-
homeSpace
- Returns
Member Data Documentation
◆ camera_ChartCenterFrame
| Vector3D ControlAPI::VCXFraming::camera_ChartCenterFrame |
Current Camera Position in ChartCenter Frame.
◆ camera_MechanicalOriginFrame
| Vector3D ControlAPI::VCXFraming::camera_MechanicalOriginFrame |
Current Camera position in mechanicalorigin Frame.
◆ camera_MountBaseFrame
| Vector3D ControlAPI::VCXFraming::camera_MountBaseFrame = {0, 24.1, -152.4} |
Camera position relative to the MountBaseFrame.
◆ chartCenter__MechanicalOriginFrame
| Vector3D ControlAPI::VCXFraming::chartCenter__MechanicalOriginFrame = {0, 1157.1, 491} |
chart center position Relative to mechanical base point. "Vector B" Units: millimeters
◆ home__MechanicalOriginFrame
| Vector3D ControlAPI::VCXFraming::home__MechanicalOriginFrame = {0, 904.8, 1978 } |
Home position of table relative to mechanical base point. "Vector A" Units: millimeters
◆ liftingColumnPort
| std::string ControlAPI::VCXFraming::liftingColumnPort |
Serial Port for Lifting Column. (ex "COM5")
◆ zaberPort
| std::string ControlAPI::VCXFraming::zaberPort |
Serial Port for zaber (ex "COM4")
The documentation for this class was generated from the following file:
- Composite_Control/Composite_Control_VCX.h